Repository navigation
3d and robot model support - #51
Closed
ah4524gdf4g5sgd5rius wants to merge 2 commits into
Closed
ah4524gdf4g5sgd5rius wants to merge 2 commits into
ah4524gdf4g5sgd5rius wants to merge 2 commits into
Conversation


|
@ah4524gdf4g5sgd5rius is attempting to deploy a commit to the baronclaps' projects Team on Vercel. A member of the Team first needs to authorize it. |
|
The latest updates on your projects. Learn more about Vercel for GitHub.
|


Member
|
the tape lines glitch in and out |
Member
|
visualized paths in 3d arent defined by the path color set on the right |
Author
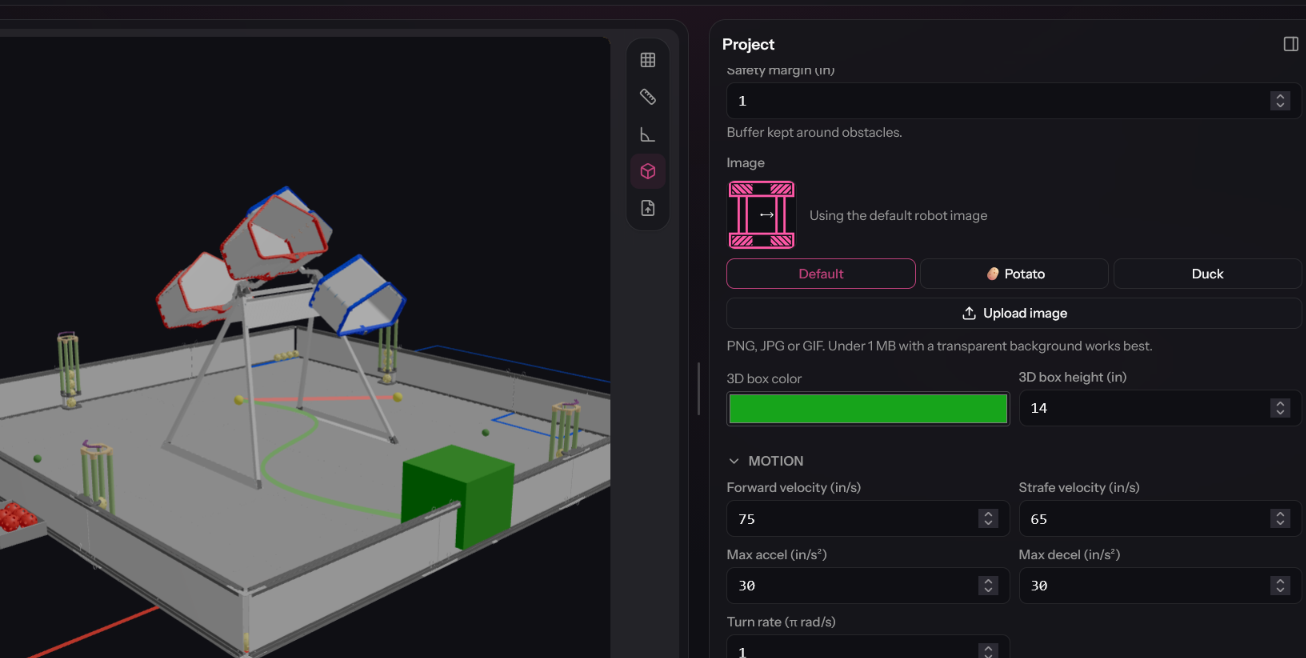 is it good now? |
fixed the lines , now the path colors and the dots are the same in 2d and 3d
Author
|
i fixed it |
Author
|
can you approve it? |

Contributor
|
Unfortunately, at this time we aren't interested in 3D visualization for the Visualizer. We appreciate the pull request and we may be more interested in the future. |

This file contains hidden or bidirectional Unicode text that may be interpreted or compiled differently than what appears below. To review, open the file in an editor that reveals hidden Unicode characters.
Learn more about bidirectional Unicode characters
Sign up for free
to join this conversation on GitHub.
Already have an account?
Sign in to comment


Add this suggestion to a batch that can be applied as a single commit.This suggestion is invalid because no changes were made to the code.Suggestions cannot be applied while the pull request is closed.Suggestions cannot be applied while viewing a subset of changes.Only one suggestion per line can be applied in a batch.Add this suggestion to a batch that can be applied as a single commit.Applying suggestions on deleted lines is not supported.You must change the existing code in this line in order to create a valid suggestion.Outdated suggestions cannot be applied.This suggestion has been applied or marked resolved.Suggestions cannot be applied from pending reviews.Suggestions cannot be applied on multi-line comments.Suggestions cannot be applied while the pull request is queued to merge.Suggestion cannot be applied right now. Please check back later.
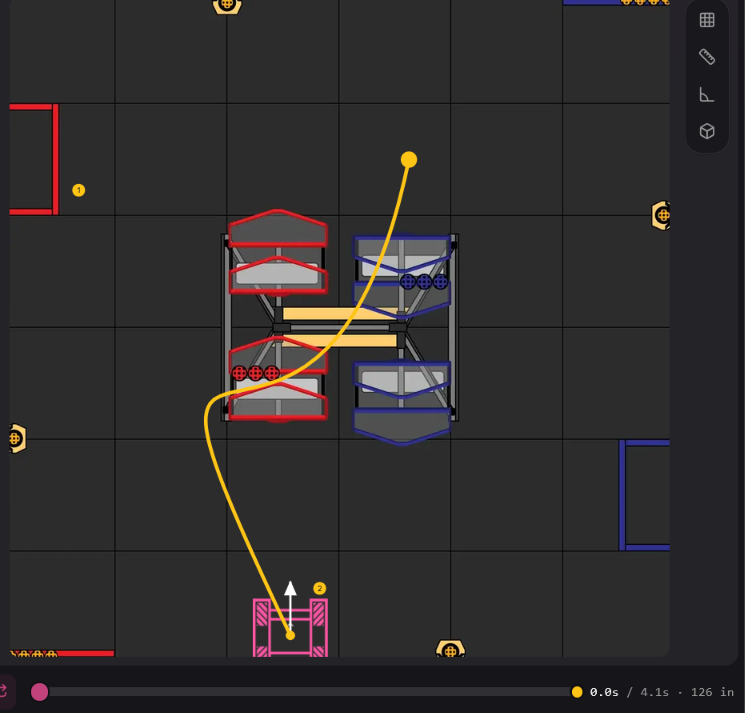
I added a btn that you can switch between 3d and 2d and a btn to upload and reset your robot model and in settings to correct your robot rotation.
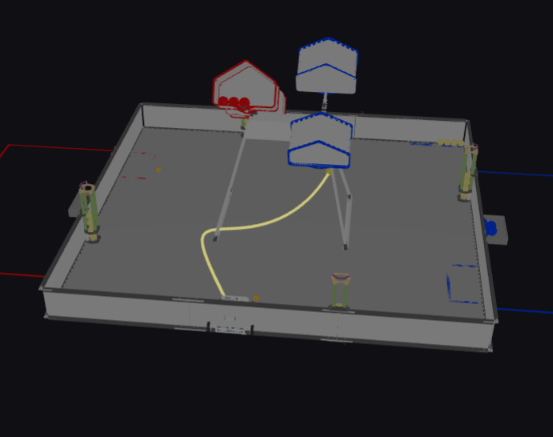
3d:
2d:
This feature can help teams to see if it hits anything bellow the hive.